Researchers from Tsinghua, Infinigence AI, and AgiBot trained 96 robots on collective experience
Read more
Pandaily
pandaily.com

Researchers from Tsinghua, Infinigence AI, and AgiBot trained 96 robots on collective experience

Researchers from Tsinghua University, Infinigence AI, and AgiBot have introduced a learning approach called Collective Experience Learning (CEL). This method allows robots to learn from the successes of other robots instead of relying primarily on human demonstrations.

According to a report published by QbitAI on October 30th, the team tested this methodology on a cluster of 96 real robots. The corresponding scientific paper is available on arXiv under the number 2610.25736.

The original problem that the researchers are solving relates to labor resources. Robots improve by accumulating practical experience, but today this is most often achieved through repeated movements by humans or operator intervention to correct errors. Although hundreds of robots can be deployed, qualified operators cannot be scaled at the same pace.

When using CEL, successful experience gained by one robot is saved and shared, allowing a robot facing a task to learn how its colleagues resolved similar situations.

Task Testing and Results

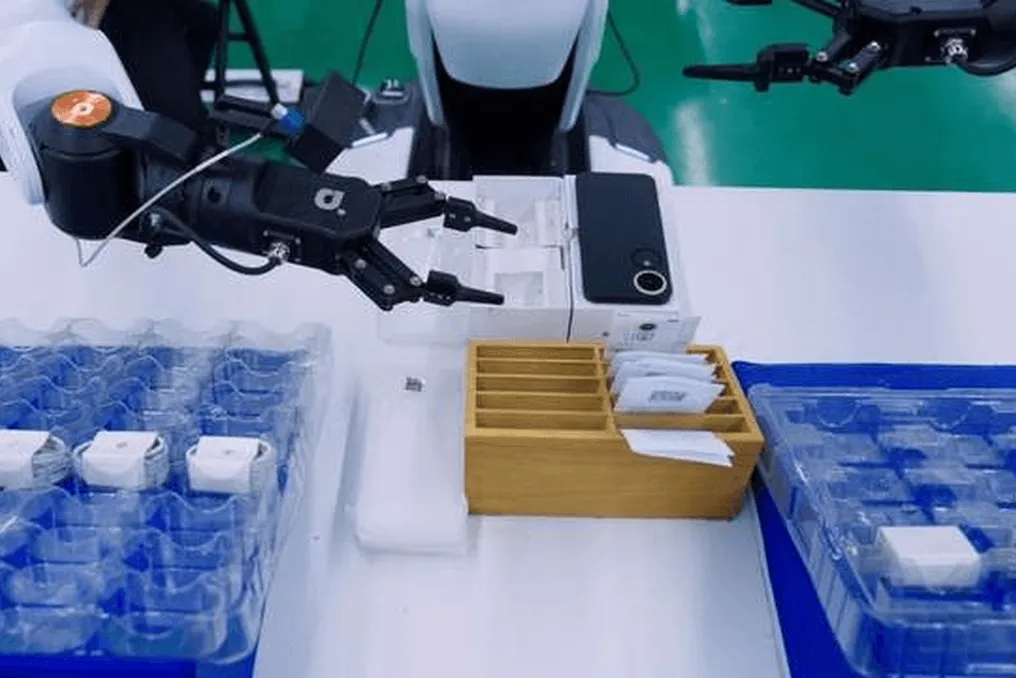
The team tested five different tasks covering both domestic and factory work: sorting colors, folding clothes, charging a phone, assembling a stool, and packaging a phone. Two robots not involved in the training performed 600 trials, incurring 15 failures, which resulted in an overall success rate of 97.5 percent. The success rate across all five tasks exceeded the average performance of six human operators.

Specifically, in phone packaging, which is a multi-stage industrial task, the success rate increased from 79.2 percent to 98.3 percent after applying collective learning, with only two failures recorded in 120 consecutive attempts.

A scaling trend was also noted: while keeping the same amount of real-time training, increasing the number of participating robots from 16 to 96 raised the success rate from 86.7 percent to 98.3 percent.

Technical Components of the System

The operation of this system is ensured by two key elements. The first is a fault-tolerant asynchronous learning system named FATS. This system is built on the open-source large-scale reinforcement learning platform RLinf. Robots upload their experience immediately after completing a task, without waiting for others, and the cluster continues to operate even if devices disconnect.

During the test with 96 robots, the cluster collected 9,834 episodes. Twenty-two robots had a total of 30 failures, but the loss of robot time was only 1.3 percent of the total operating time.

The second component is an algorithm called failure-guided experience retrieval fine-tuning (FERT). One manipulation can last minutes and involve thousands of action steps, but feedback often boils down only to final success or failure. FERT uses both aspects: when a robot encounters difficulties, it retrieves successful experience from analogous situations and focuses the learning specifically on these examples.

The report was provided by Infinigence AI. The results are presented by the research group and have not yet undergone independent verification.
Similar stories

X Square Robot introduces X2Real—an evolving simulation benchmark for robot evaluation
Read more
pandaily.com

X Square Robot introduces X2Real—an evolving simulation benchmark for robot evaluation

The embodied artificial intelligence startup X Square Robot has released X2Real—a simulation benchmark designed to measure the performance of fundamental level robot models in the real world, as well as to continuously expand the test dataset as models improve.

The company clearly states the problem: evaluating real robots is costly and slow, whereas simulation is fast but often unrealistic and allows models to easily overfit. X2Real is based on three principles: fidelity, efficiency, and fairness.

To ensure fidelity, the team recorded trajectories from physical robotic manipulators, reproduced the same control commands in the simulation, and tuned joint responses until they matched, which the company claims ensures trajectory consistency at the millimeter level. Visual appearance and physical characteristics, such as contact, were also calibrated. Supported embodiments include the single-arm Franka, the two-arm ArtiXon Arm-6A, ARX R5, and the mobile manipulator Quanta X1. When performing general manipulation tasks, X Square Robot reports a correlation of 0.96 between task success in simulation and in the real world, and 0.99 for progress metrics. This data was obtained through the company's own tests on this subset of tasks.

Regarding efficiency, X2Real includes 44 tasks distributed across 10 categories. Four categories are dedicated to reasoning: generalization, visual understanding, language comprehension, and memory. Five categories relate to manipulation: fine manipulation, two-arm coordination, tool use, dynamic objects, and mobile manipulation. A separate set of tasks, including block stacking, pressing buttons in a specified color sequence, and solving the Tower of Hanoi, is aimed at testing accuracy, long-term memory, and planning. The company notes that most existing models still struggle with these tasks.

The principle of fairness is achieved by independently randomizing the appearance, task setup, and embodiment conditions. Models trained after this stage use a dataset collected over nearly 300 hours in a studio with a uniform green screen, which is separate from the evaluation scenes. The benchmark operates within the Mana simulation ecosystem, built on NVIDIA Isaac Lab-Arena, which packages scenes, robots, and task steps into reusable modules.

AI agents manage two loops. One generates new tasks and scenes from a limited menu of options with automatic checking to exclude incorrect settings. The second breaks down each task into a subgraph of subtasks, evaluates each node based on object poses, contacts, and grasp states, and creates intentionally new tests where the model fails.

A unified protocol called Policy Space standardizes differences in input formats, action representations, and output timing. Developers perform inference locally and connect to a platform that handles online evaluation and trajectory replay without requiring a local simulation setup.

OpenAI to develop humanoid robots; first demonstration expected in 2027
Read more
www.aajtak.in

OpenAI to develop humanoid robots; first demonstration expected in 2027

OpenAI, the company that created ChatGPT, plans to undertake an even larger project—the development of robots that resemble humans externally. Special attention is paid not only to these robots' ability to move but also to their capacity to understand their environment and perform tasks.

OpenAI CEO Sam Altman has hinted at a robot demonstration. This raises questions about the robot's capabilities and its expected arrival timeline.

First demonstration possible in 2027

According to a report, Sam Altman stated that OpenAI could present a demonstration of its humanoid robot in 2027. However, the company has not yet disclosed full information regarding the release date, price, or characteristics of the robot, and this does not mean it will go on sale specifically in 2027.

A natural question arises regarding the necessity of creating humanoid robots, given that machines already exist. Modern homes, offices, and factories are designed with human anatomy in mind. A robot with a structure similar to a human can function more easily in such environments.

However, simply creating a human body is not enough. The robot must possess the ability to analyze what is happening around it and make decisions about subsequent actions.

The robot's brain will be the most important

OpenAI's main strength lies in its artificial intelligence technologies. The company intends to use this technology to give the robot intelligence. For example, if the robot is tasked with picking up an object, it must first recognize the object, understand how to lift it, and then complete the task. Thus, what becomes critically important is not just following pre-set commands, but the robot's ability to make decisions based on understanding the current situation.

Competition with Tesla?

OpenAI is not the only company participating in the humanoid robot race. Tesla, led by Elon Musk, is also working on its Optimus robot. Other companies are also advancing this technology.

Currently, complete information about the OpenAI robot is unavailable. It remains to be seen what the company will demonstrate in 2027 and how effectively its robot will be able to operate in the real world.

Popular